ztl34245881-commits/dsh-task-planner
Task planning with experience muscle-memory for DeepSeek Harness: condition-reflex recall + LLM capability matching + auto-persisted lessons
已收录
4
Workflow
Bundle 已验证
预览
功能介绍
带经验肌肉记忆的任务规划:条件反射检索历史方案 + LLM 能力匹配 + 经验自动沉淀。
适合
- 规划复杂或重复任务、且历史方案能为下一次计划提供参考的团队。
- 需要根据可选技能与插件目录为任务步骤匹配能力的 Agent。
- 希望把草稿和已验证经验以可人工编辑 Markdown 持久化,供后续检索的用户。
不适合
- 简单的一次性任务,因为规划、检索和经验沉淀带来的流程可能大于价值。
- 缺少文档要求的 `llm`、`shell` 或 `tools` 服务的环境。
- 禁止持久保存任务记录的工作流,因为规划会自动创建经验草稿。
- 要求确定性规则规划的用途;能力选择和复用判断由 LLM 驱动。
README
dsh-task-planner
Task planning with experience muscle-memory for DeepSeek Harness (dsh).
Give a task → the agent recalls past similar solutions (condition reflex), evaluates whether they fit, and produces a dynamic plan matched against its capabilities — never hard-coded combos. Every plan auto-drafts a lesson into the experience library; when the task closes, the agent updates the outcome. The more you work, the smarter the reflex.
Features
- 🧠 Experience library (
task_memory save/recall/list): persistent lessons as plain Markdown with signature keywords. Recall uses a 2–3-char sliding-window tokenizer, so “weekly report” still hits a “daily report” lesson. - ⚡ Condition-reflex planning (
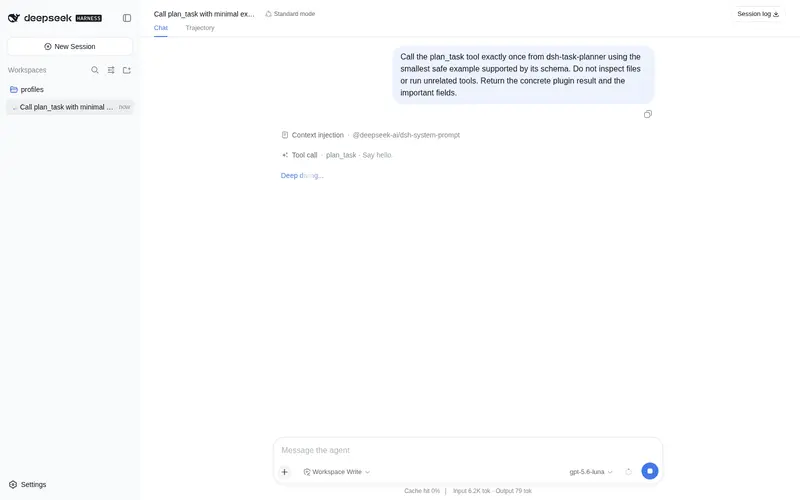
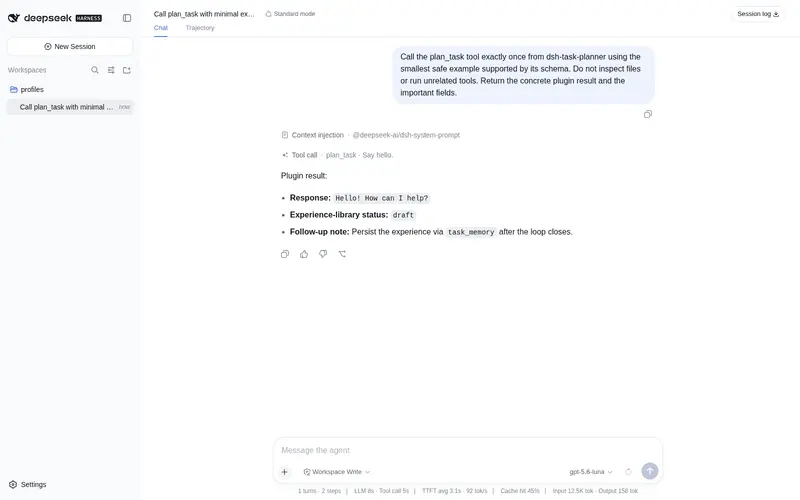
plan_task): recall → LLM evaluates fit (reuse & improve, or explain why not and plan fresh) → decomposed steps with capability matching → risks → next actions. - 🤖 LLM-driven, not rule-driven: the model decides what to use per task; the plugin only supplies context (past experiences + optional capability catalog).
- ✍️ De-AI deliverable standard: any textual output step (docs/sheets/slides/copy/scripts) must include a humanize-then-review pass before delivery.
- 🗂️ Auto-persist:
plan_taskdrafts the lesson automatically (status:draft); the agent marks itverifiedwith the outcome at loop close. - 🔒 Zero keys, zero absolute paths: everything is configurable; the experience library lives in
~/.dsh/planner-lessonsby default.
Install
dsh plugin --profile web add github:<your-user>/dsh-task-planner
or copy the repo and add it as a local bundle:
dsh plugin --profile web add /path/to/dsh-task-planner
Config (optional, in your profile’s cordis.patch.yml)
- id: dsh-task-planner
  name: dsh-task-planner
  config:
    lessonsDir: /path/to/your/lessons   # default: ~/.dsh/planner-lessons
    capabilityFile: /path/to/capability-map.md  # optional catalog fed to the LLM
Point capabilityFile at a markdown catalog of your skills/plugins (e.g. an awesome list) and plan_task will match each step against it.
Usage
-
plan_task { task, goal?, constraints? }— plan before starting complex work. -
task_memory save { task, plan, outcome }— persist a lesson (auto-called by plan_task for the draft). -
task_memory recall { task }— condition-reflex lookup. -
task_memory list— show all lessons.
Lesson lifecycle
-
plan_taskwrites a draft lesson (status: draft) automatically. - When the task closes, the agent updates it with the outcome (
status: verified). - A lesson reused successfully 3× → promote to a formal skill. A lesson rejected 2× → mark obsolete.
Notes
- Requires the
llm,shell,toolsservices (all present in the standard harness). - The model call uses the harness default model (
agentDefaultModel); reasoning models need a generousmaxTokens(8k is used internally). - Lessons are plain Markdown — human-editable, greppable, portable.
License
MIT
常见问题常见问题
在启用了 DSH 的终端中执行已验证命令 dsh plugin --profile default add github:ztl34245881-commits/dsh-task-planner。命令会解析公开 package 元数据,并保持插件与本页展示的目录身份一致。
兼容性以页面上展示的 bundle 与 profile 状态为准。如果某个 profile 尚未检测到,请先保持禁用,并在生产启用前阅读仓库文档。
GitHub 链接和 activity 元数据是 release 与维护状态的来源。新版本发布后重新查看本页,确认目录已经观察到最新版本。